Introduction
A site review often needs more than still photographs taken from the ground. Reality capture is the practice of recording visible conditions at a stated time so someone who was not there can examine geometry and relationships. Photogrammetry is the part of that practice that reconstructs shape from overlapping photographs.
Photogrammetry can turn overlapping still photographs into a navigable 3D record. The result is not a cinematic visualization first. It is a way to preserve site geometry so later reviewers can look around, check relationships, and compare conditions without standing on the site.
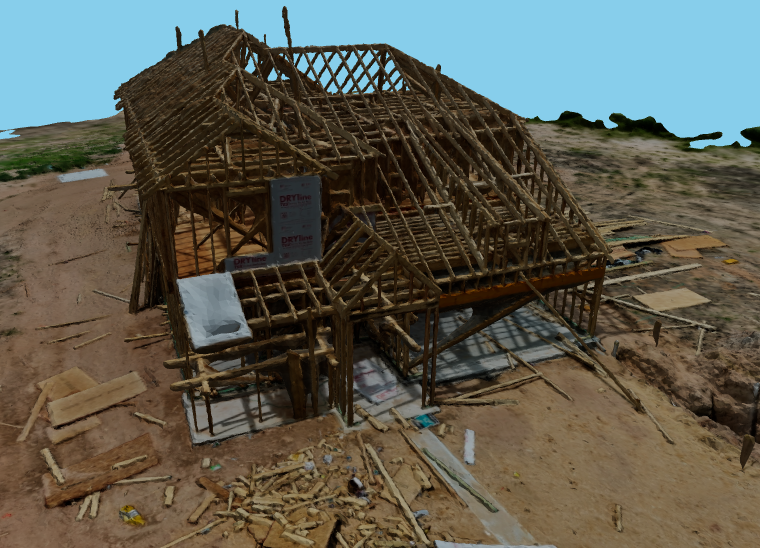
The viewer below is a photogrammetric mesh from the custom-home 3D reconstruction project. Rotate and zoom to inspect the structure. A browser-based Pix4D preview of the same dataset is also available for comparison.
This article explains how those photographs become a point cloud and then a textured mesh, and what affects whether the mesh is complete enough to inspect. The model above is an example of that product. The article does not decide whether a measurement from a model is appropriate for design, fabrication, or a survey, and it does not report dimensions or findings for the house shown here.
How photogrammetric 3D models are made
The viewer shows a finished mesh. The sequence below is how a mesh of that kind is produced.
Capture follows a planned pattern with high overlap so the same surfaces appear in many photographs. Processing software identifies common features, estimates camera positions, and builds a point cloud. That cloud can be converted into a mesh, then textured with the original photographs.
- Image capture. Grid or orbital passes collect overlapping stills. Speed, altitude, and camera settings are kept consistent to reduce gaps.
- Point cloud. Photogrammetry software aligns the photographs and triangulates tie points into a dense 3D point set.
- Mesh and texture. The point cloud becomes a surface, and photographic texture is applied so the model can be inspected visually as well as spatially.
The same image set can also produce an orthomosaic. Understanding orthomosaic mapping covers that 2D output. Mapping and photogrammetry describes when SterFlies uses these methods on a project.
A point cloud is a set of positions in three-dimensional space, each estimated where the same surface detail was seen from more than one photograph. The mesh connects those points into faces, and the texture paints the faces with the photographs. A surface that appears in only one or two frames may never become a reliable set of points, so the mesh can contain a hole or a stretched face there. Glass, standing water, and objects that moved between frames are common causes. Visual smoothness is not the same thing as a well-sampled surface.
Where 3D reconstruction is useful
The processing sequence explains the file. Usefulness depends on whether a later reviewer needed geometry rather than a single viewpoint.
A navigable model is most useful when later reviewers need geometry, not just a selected viewpoint:
- Construction and existing conditions. As-built context, progress comparison, and coordination when the site is changing.
- Site layout and terrain. Relating structures, grades, and access in three dimensions.
- Volume context. Surfaces derived from photogrammetry can support volume discussion when a capture is scoped for that output. Reported tolerances vary with method and control; they are not a guaranteed inventory accuracy.
On a building or a site layout, the useful question is often relational. A reviewer can look at how a roof meets a wall, how grade approaches an entry, or how a piece of equipment sat beside an access path, without being limited to the camera angles chosen in the field. The house model above is that kind of inspection. Volume context is a further product: the space between two surfaces, estimated only when the capture was planned for the comparison. That estimate does not identify material type, compaction, or ownership, and it does not become a payment quantity merely because a mesh exists.
What affects model quality
Relational inspection still fails where the photographs were thin, blurred, or poorly placed.
More well-placed photographs usually produce a denser, more complete surface. Overlap, ground sample distance, lighting, and camera stability all matter. RTK positioning can improve the geospatial placement of a model when it is part of the capture plan. It does not, by itself, make every measurement “centimeter accurate.”
- Overlap. Surfaces seen in many photographs reconstruct more reliably than surfaces seen in one or two frames.
- Ground sample distance. Lower altitude or a higher-resolution sensor records finer texture. That is a resolution choice, not a survey specification.
- Lighting and motion. Harsh shadows, blur, and mixed exposures reduce feature matching.
Ground sample distance (GSD) is the ground width represented by one pixel. It depends mainly on how far the camera is from the surface and on the sensor and lens. A finer GSD records smaller texture, which gives feature matching more detail. It does not state how far a point in the model may lie from a position established by a surveyor.
Real-time kinematic (RTK) positioning corrects the camera’s satellite position during capture, using a base station or a network correction, and stores that position with the photographs. Those positions help place the model in a coordinate system. Placement and surface detail are different properties. A model can sit in a useful coordinate frame and still miss a wall the camera never saw.
Field practices that help
The factors above are properties of the capture. Field habits are how they are held steady on the day.
- Plan the flight or capture path for the surfaces that matter, including edges and vertical faces when those are in scope.
- Lock camera settings so exposure stays consistent across the set.
- Avoid wind, rain, and rapidly changing light when possible.
- Review the image set before processing and exclude frames that are blurred or unusable.
The practical benefit is later review: people who were not on site can still inspect the captured geometry. That can reduce some return visits. It does not replace field verification when a decision requires it.
Consistent exposure matters because matching compares patterns from frame to frame. A set that swings from deep shadow to blown highlights gives the software fewer stable marks. Reviewing the set before processing is the chance to remove frames that would pull the solution toward a bad camera position. Later inspection can be thorough only for the surfaces the remaining frames contain.
Limitations
A photogrammetric mesh is a model of visible surfaces sampled from the photographs that were kept. It omits interiors unless those spaces were photographed with their own overlap. It omits the far side of objects, the ground under a stockpile or a vehicle, and any face seen too few times to reconstruct. A browser model may also be simplified so it can load. The viewer is for inspection of shape and appearance, and a simplified mesh can drop small geometry that still exists in the original processing project.
The model does not explain why a condition exists, and it does not grade the work. A gap or an uneven surface can be looked at in context. Where a dimension has to be checked, the model is a guide to where to look and a record of what was visible. The check follows the method the decision requires.
Conclusion
Overlapping photographs, aligned by photogrammetry, produce a point cloud. That cloud can be meshed and textured so a later reviewer can move through the captured geometry instead of assembling the site from separate stills. Overlap, ground sample distance, lighting, and camera position, including RTK when the plan uses it, govern how complete that geometry is and how it sits in coordinates.
The practical result is shared inspection. Construction, safety, and design reviewers can see relationships among structure, grade, and access, and they can return to the same model after the site has changed. An orthomosaic from the same frames provides the map view. Close photographs and, when a decision requires them, field measurements still carry the determinations a surface cannot make.
The model is not a survey, not a diagnosis, not a finding of causation, and not inventory control. It is a record of visible geometry under a stated capture plan. Reviewers use it to see that geometry. The determination their role requires stays with them.